Intent read from EMG
Grasp is derived from muscle electrical activity. No extra joystick to memorise.
EMG-controlled domestic bionic hand.
An EMG-controlled bionic hand developed in 2018 to drive a prosthesis from muscle signals.
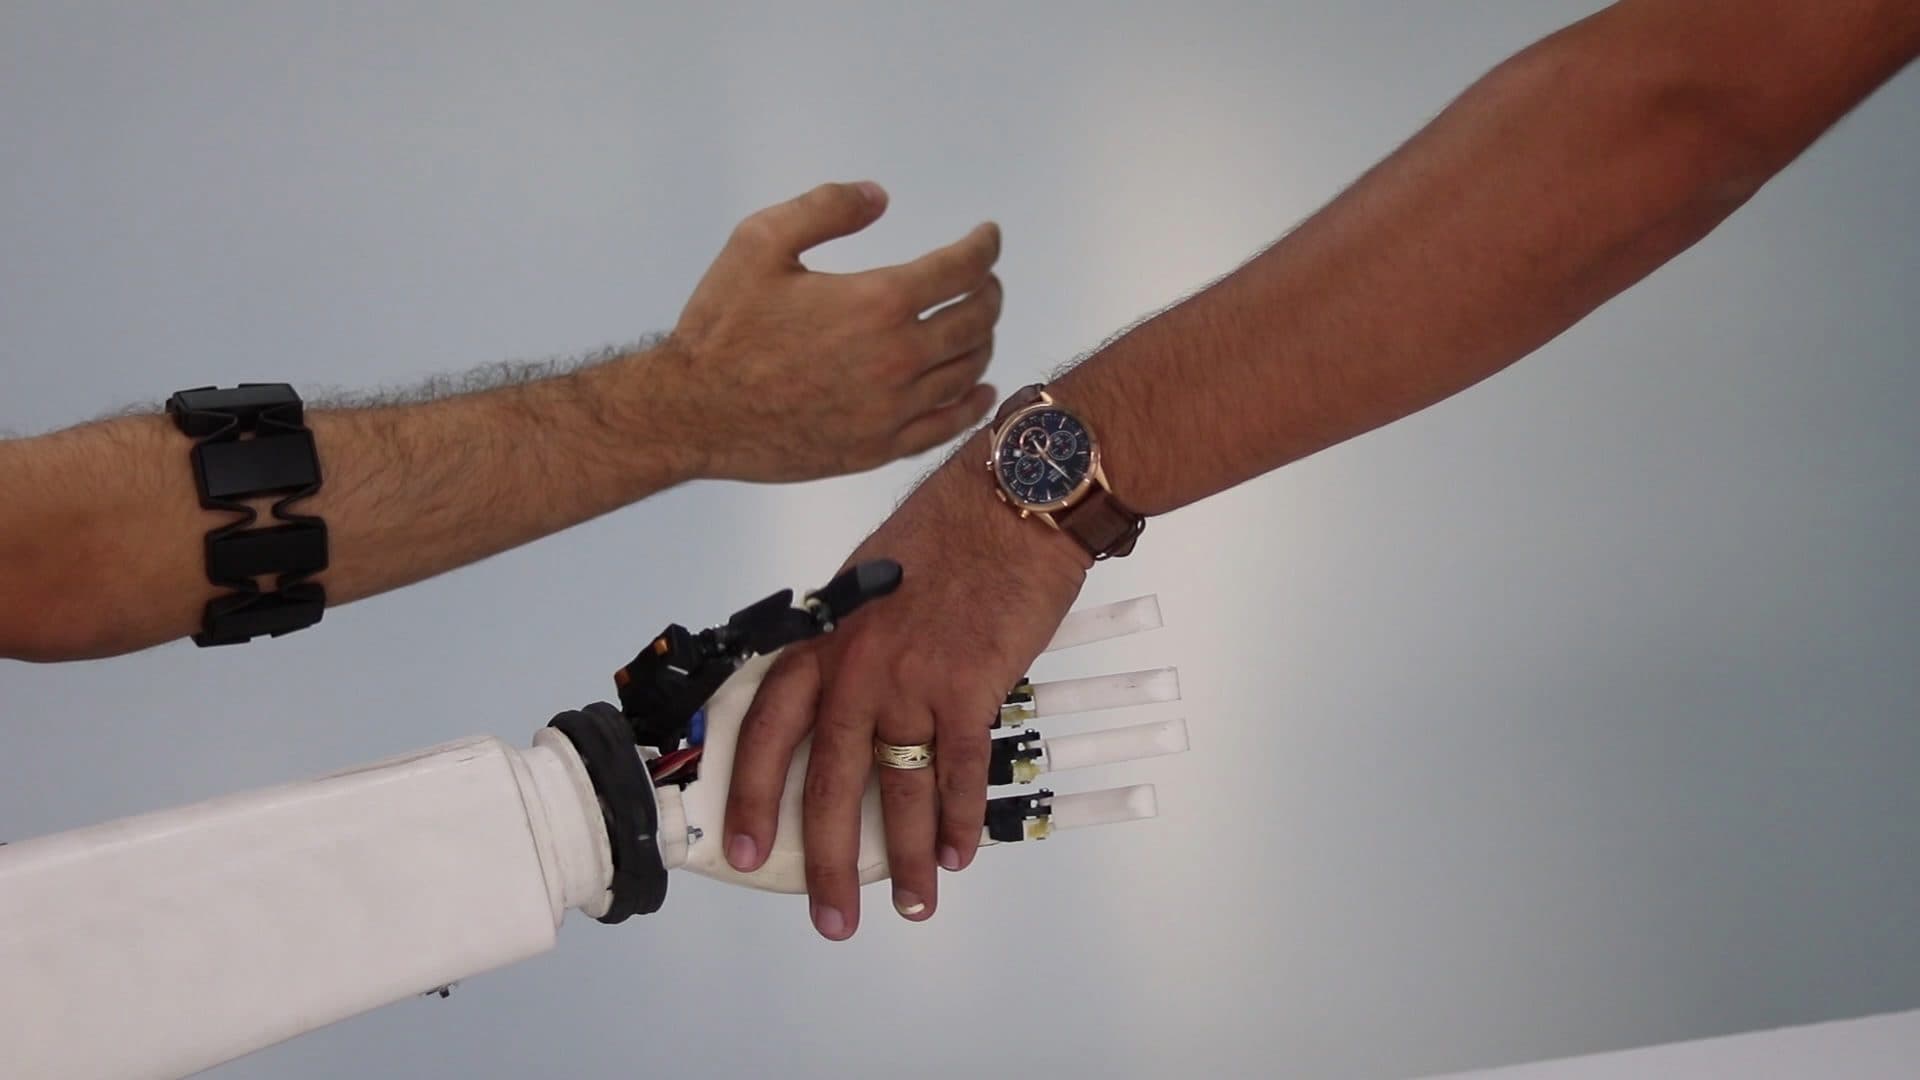
In 2018 İtech Robotics began work on an EMG-controlled domestic bionic hand.
The goal is natural, reliable grasping by reading user intent from muscle electrical activity.
Grasp is derived from muscle electrical activity. No extra joystick to memorise.
Work on the hand has run in the Isparta R&D centre since 2018 — not software on an imported shell.
The aim is reliable, repeatable hold on everyday objects, not a demonstration.
It grows with user and physician feedback before it is treated as a catalogue SKU.
No PDF is online for this product yet. We can send it to you.
Request documents01
We plan the layout, power and daily routine with you.
02
The robot is installed, tested and your team is trained on site.
03
Service, spare parts and remote support stay with you.
It is an R&D outcome in our health-technology portfolio. Contact us for the current status.